Sigmoidal
  • Home
  • LinkedIn
  • About me
  • Contact
No Result
View All Result
  • Português
  • Home
  • LinkedIn
  • About me
  • Contact
No Result
View All Result
Sigmoidal
No Result
View All Result

Feature Store Summit 2026: A Free Production AI Conference

Carlos Melo by Carlos Melo
October 2, 2026
in Data Science, Machine Learning, Posts
0
23
VIEWS
Share on LinkedInShare on FacebookShare on Whatsapp

How often do you get the chance to learn from the leading references in a field, gathered in a single day and at no cost? That is what the Feature Store Summit 2026 offers on Tuesday, October 6.

This invitation is a personal recommendation. The summit is a free online conference, organized by Hopsworks, that brings together engineers who build the machine learning systems at Uber, Spotify, and Airbnb. I consider it a rare opportunity for anyone who wants to understand how AI works in production, far from the controlled environment of courses and notebooks.

CLICK HERE TO REGISTER FOR FREE!
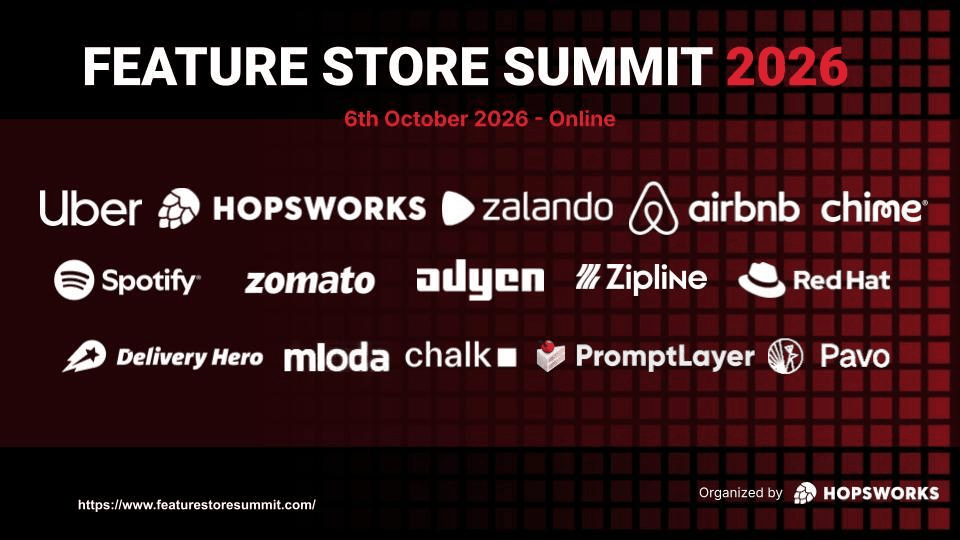
Official Feature Store Summit 2026 banner for the online event on October 6, with the logos of Uber, Spotify, Airbnb, Adyen, Zomato, Zalando, Red Hat, and other participating companies.

Why the Feature Store Summit 2026 deserves your time

The opening session is delivered by Jim Dowling, CEO and co-founder of Hopsworks, associate professor at KTH Royal Institute of Technology in Stockholm, and author of Building Machine Learning Systems with a Feature Store, published by O’Reilly. I have followed his work for a long time, read the early-release version of the book, and continue to recommend the Hopsworks material to anyone who intends to take models to production.

If the term is new to you, a feature store is the infrastructure layer that computes, stores, and serves the input variables of a model, so that training and inference work with the same values. In this sixth edition, the discussion extends to AI agents, which depend on fresh, real-time context to produce reliable answers.

The talks I do not plan to miss

What caught my attention in the program is that a large share of the 17 talks covers real cases, presented by the people who built them. These are the four I do not plan to miss (all times in UTC):

  • Uber (16:30): how to keep features consistent between training and production in large-scale search and ranking models.
  • Red Hat (17:30): how to build agents on governed context by combining Feast, MLflow, and OGX.
  • Spotify (18:40): how to look up a single key directly in the Parquet files of a data lake, accepting a little more latency in exchange for a considerable reduction in cost.
  • Airbnb (20:30): how a generative recommender moved from daily batch processing to near-real-time updates.

The full agenda runs from 15:30 to 22:00 UTC (11:30 a.m. to 6:00 p.m. Eastern Time) and also includes teams from Adyen, Zomato, Zalando, and Delivery Hero. In addition, every registrant is entered into a draw for either a copy of the book signed by the author or €1,000 in Hopsworks platform credits.

Even if you cannot follow the entire event, I recommend registering and choosing the sessions closest to your own projects. Hearing how these teams reason about cost, latency, and consistency broadens your repertoire and helps you see the path between a trained model and a production system. Registration is free and available on the official Feature Store Summit website.
Register for free

ShareShareSend
Previous Post

YOLO26: What Changed in Object Detection

Carlos Melo

Carlos Melo

Computer Vision Engineer with a degree in Aeronautical Sciences from the Air Force Academy (AFA), Master in Aerospace Engineering from the Technological Institute of Aeronautics (ITA), and founder of Sigmoidal.

Related Posts

Urban YOLO26 scene with one bus and four pedestrians, each outlined once to represent end-to-end object detection
Computer Vision

YOLO26: What Changed in Object Detection

by Carlos Melo
August 28, 2026
Follower drone using a four-microphone array to estimate bearing and range from the natural propeller sound of a leader drone
Aerospace Engineering

SonicFly: How Drones Pursue Each Other by Sound

by Carlos Melo
August 21, 2026
Urban intersection in which a DETR-style detector assigns one prediction box to each pedestrian, cyclist, vehicle, bus, and traffic light
Computer Vision

DETR: Object Detection as Set Prediction

by Carlos Melo
August 20, 2026
Industrial data pipeline with English-labeled stages for scaling, imputation, encoding, and modeling
Machine Learning

Scikit-Learn Pipelines: Prevent Data Leakage

by Carlos Melo
July 6, 2026
Probability surface and linear decision boundary learned by logistic regression on two overlapping classes
Data Science

Binary Cross-Entropy and Logistic Regression

by Carlos Melo
June 1, 2026

Leave a Reply Cancel reply

Your email address will not be published. Required fields are marked *

  • Trending
  • Comments
  • Latest

Real-time Human Pose Estimation using MediaPipe

September 11, 2023
ORB-SLAM 3: A Tool for 3D Mapping and Localization

ORB-SLAM 3: A Tool for 3D Mapping and Localization

April 10, 2024

Build a Surveillance System with Computer Vision and Deep Learning

1
ORB-SLAM 3: A Tool for 3D Mapping and Localization

ORB-SLAM 3: A Tool for 3D Mapping and Localization

1
Point Cloud Processing with Open3D and Python

Point Cloud Processing with Open3D and Python

1

Fundamentals of Image Formation

0
Official Feature Store Summit 2026 artwork showing the event name and the date, October 6, 2026, in a virtual format.

Feature Store Summit 2026: A Free Production AI Conference

October 2, 2026
Urban YOLO26 scene with one bus and four pedestrians, each outlined once to represent end-to-end object detection

YOLO26: What Changed in Object Detection

August 28, 2026
Follower drone using a four-microphone array to estimate bearing and range from the natural propeller sound of a leader drone

SonicFly: How Drones Pursue Each Other by Sound

August 21, 2026
Urban intersection in which a DETR-style detector assigns one prediction box to each pedestrian, cyclist, vehicle, bus, and traffic light

DETR: Object Detection as Set Prediction

August 20, 2026
Instagram Youtube LinkedIn Twitter
Sigmoidal

O melhor conteúdo técnico de Data Science, com projetos práticos e exemplos do mundo real.

Seguir no Instagram

Categories

  • Aerospace Engineering
  • Blog
  • Carreira
  • Computer Vision
  • Data Science
  • Deep Learning
  • Featured
  • Iniciantes
  • Machine Learning
  • Posts
  • Tutoriais
  • tutorials

Navegar por Tags

3d 3d machine learning 3d vision bayer filter camera calibration clahe computer vision custom dataset data science deep learning depth anything depth estimation digital image processing fine-tuning grad-cam histogram histogram equalization image formation job lens machine learning machine learning engineering mediapipe object detection open3d opencv python pytorch quantization redes neurais resnet roboflow rocket sampling scikit-learn space tensorflow transfer-learning transformer tutorial vision-transformer visão computacional vit yolov8 yolov9

© 2024 Sigmoidal - Aprenda Data Science, Visão Computacional e Python na prática.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In

Add New Playlist

No Result
View All Result
  • Home
  • Mentoria
  • Cursos
  • Blog
  • Sobre Mim
  • Contato
  • Português

© 2024 Sigmoidal - Aprenda Data Science, Visão Computacional e Python na prática.